Motion Core
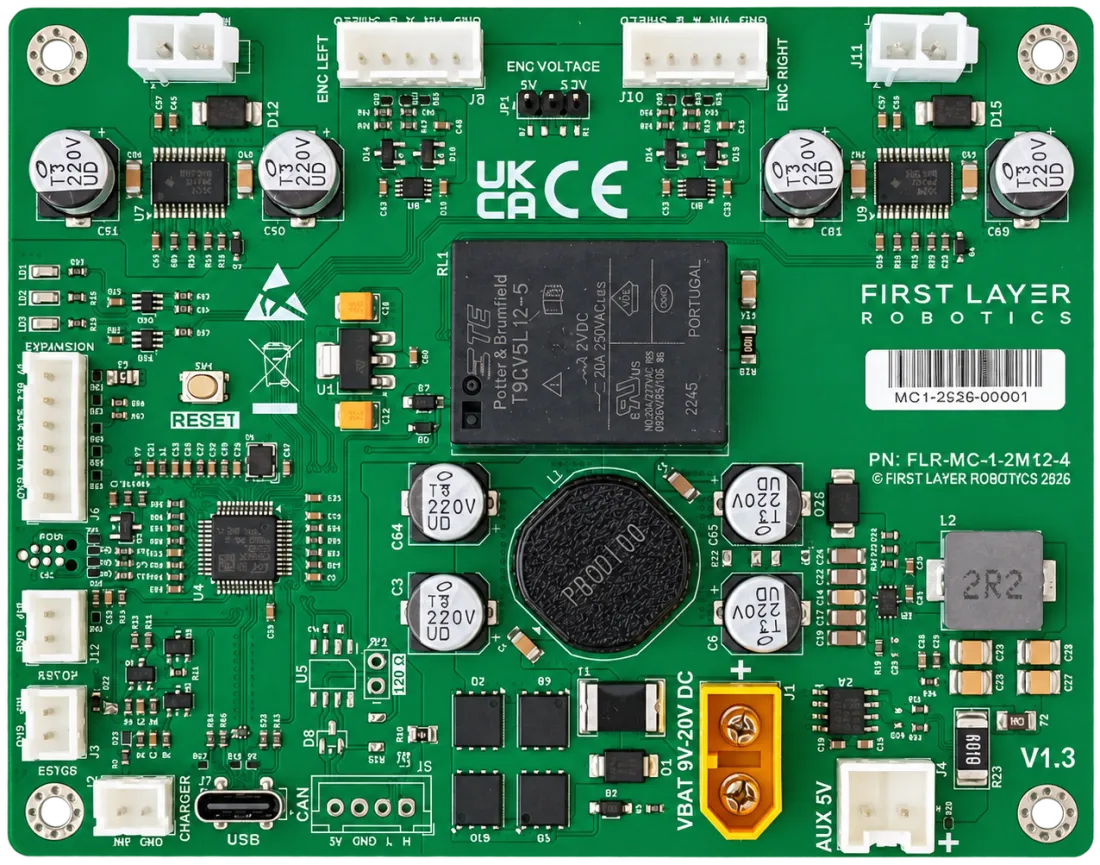
A USB-connected motion subsystem that runs under any Linux host or ROS 2 stack, including NVIDIA Jetson and Raspberry Pi — integrating motor control, wheel-velocity PID, kinematics, power distribution and a hardware safety architecture in a single robotics-native platform.
All built on ORCP — an open protocol with ready-to-use Python and ROS 2 libraries — so you're sending velocity commands within minutes, not weeks.
Why Motion Core?
Traditionally, every team has to solve motor control, encoder timing, power sequencing and safety from scratch — burning months on infrastructure that has nothing to do with what makes their robot unique. Motion Core hands you that foundation as a characterised, serialised, protocol-compliant module, so your engineering time goes into your application, not your low-level stack.
Reduce Repeated Engineering
Replace bespoke motor-control electronics and custom firmware with a reusable robotics motion subsystem.
Accelerate Development & Reduce Risk
Cut development time and de-risk your project with hardware that's already characterised, qualified and ready to drive.
Focus On Autonomy
Let robotics teams focus on perception, controls, navigation and application behaviour rather than embedded infrastructure.
Typical System Architecture
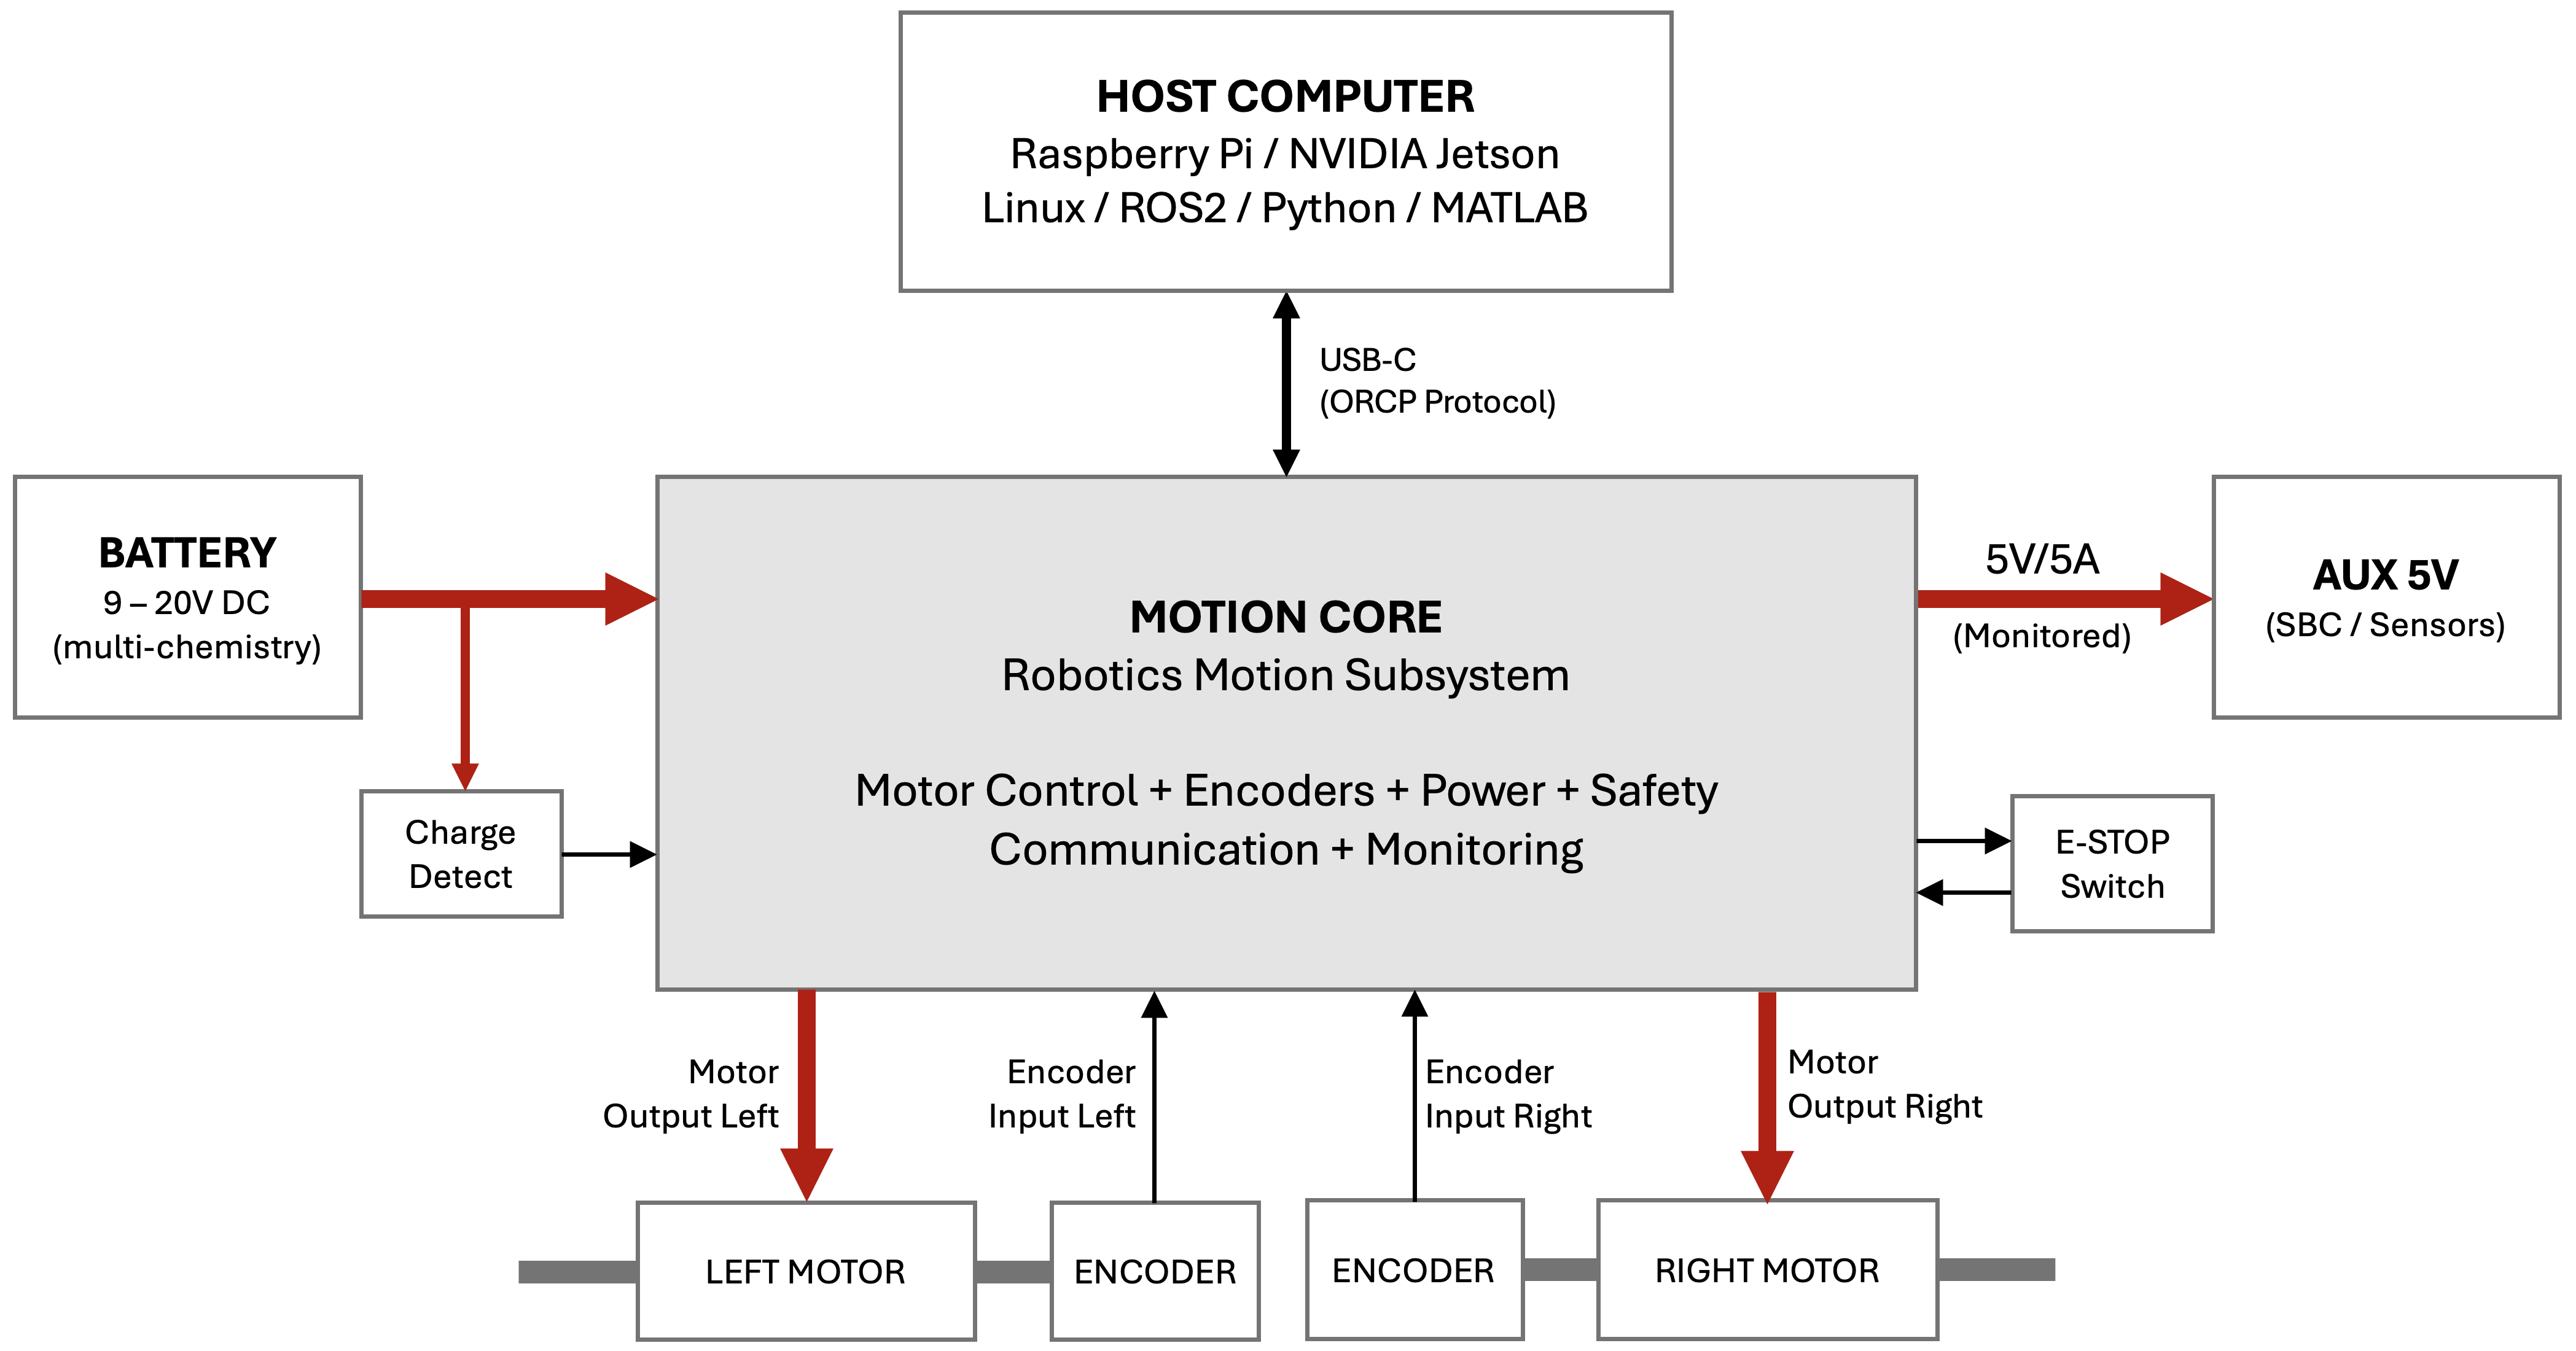
Motion Core sits between the host computer and the robot’s motors and power system, providing a complete motion subsystem over a single USB connection.
Key Capabilities
Single USB Integration
One cable from host SBC to motion subsystem. No bespoke embedded layer to build, debug or maintain.
Differential-Drive Control
On-board wheel velocity PID, encoder acquisition and kinematics for differential-drive robots.
Open Protocol
ORCP (Open Robotics Communication Protocol) provides a clean abstraction between software and motion hardware.
Robotics-Native Software
Designed for Python and ROS 2 integration, with MATLAB support coming soon — not just low-level register or PWM control.
Integrated Power Architecture
Multi-chemistry battery monitoring, 5V / 6A auxiliary output and current monitoring for SBCs and sensors.
Safety-Oriented Design
Hardware E-stop, safe-start interlock and motor-disable logic designed in from the architecture upward.
Resources
Documentation and tools to help you integrate Motion Core into your robot.
Data Sheet
Detailed electrical and mechanical specifications, pinout, and operating envelope.
Getting Started · Python
Connect a board, install the Python library and send your first velocity command.
Getting Started · ROS 2
Bring Motion Core up as a ROS 2 node and drive a differential-drive robot.
Web Configurator
Browser-based tool to inspect, configure and update connected Motion Core boards over USB.
ORCP Specification
Open Robotics Communication Protocol — the open wire format Motion Core speaks.
Ready to build on Motion Core?
Pre-order the board on its own, or add the Cable Kit and Shorting Links — every unit ships fully characterised, serialised and ready to drive. Prices exclude VAT and shipping, both calculated at checkout.